Hey everyone, I’m Jake, part of the team that supplies RF hypoid gear motors—if you’ve ever needed a compact, torque-dense power source for robotics, medical devices, or even mobile automation gear, you’ve probably worked with something we make. One question I get asked all the time, both by engineers building custom prototypes and small business owners testing new products, is: “What’s the absolute maximum speed an RF hypoid gear motor can hit?” It’s not a straightforward number, and I’ve seen way too many people just grab a generic gear motor spec off a catalog and hope it works for their build. Let’s break this down like we’re shooting the breeze in a workshop, no stuffy engineering jargon that’ll make your eyes glaze over. RF Hypoid Gear Motor

First, let’s get on the same page about what an RF hypoid gear motor is, because a lot of folks mix these up with standard spur gear motors. A hypoid gear set is like a spiral bevel gear, but the pinion (the small gear connected to the motor shaft) is offset from the center of the ring gear. That offset is the secret sauce—lets you cram more torque into a smaller package, and it also changes how the gears interact when they’re spinning fast. “RF” here just means “radio frequency,” which for our motors translates to the high-frequency brushless design most of our units use now, since brushed motors can’t handle the RPMs we’re gonna talk about without burning out.
Now, the maximum speed of an RF hypoid gear motor isn’t a single number—way too many people treat it like that. It depends on three big factors: the gear ratio, the type of bearings we use for the gear set, and the load on the motor. Let’s start with gear ratios because that’s the first thing most people adjust. Hypoid gear motors are built with gear reductions, right? A typical ratio might be 5:1 (low reduction, high speed) all the way up to 200:1 (high reduction, slow speed). If you take a 5:1 RF hypoid gear motor that’s rated to spin at its input shaft (the motor itself) at 5000 RPM, your output speed is 1000 RPM. If you crank the ratio up to 20:1, that 5000 RPM input drops to 250 RPM output, and at 100:1, it’s just 50 RPM. But here’s the thing: the input speed (the motor’s own RPM) isn’t the limit. The gear set’s teeth and bearings are what cap how fast the output can spin without grinding or wearing out fast.
I’ve seen some of our high-reduction units (100:1 to 150:1) hit output speeds around 500 to 750 RPM, but that’s with very light loads—like moving a small camera gimbal, where the motor barely has to push anything. But if you load that same unit up with, say, a small automated door actuator (which needs steady torque to move the door), you’re lucky to get 200 RPM before the gear teeth start making that weird whirring noise that means metal is rubbing too hard. On the flip side, our ultra-low reduction units (3:1 to 7:1) can handle way higher output speeds, because the gear teeth aren’t under as much stress from the reduction. We’ve tested those unloaded, no-load, at output speeds up to 3000 RPM. Wait, that’s wild, right? But that’s unloaded. If you put even a moderate load on it—like pulling a 1kg cart along a flat surface—that drops to around 1800 RPM, and a heavy load (5kg) knocks it down to 1200 RPM.
Next up, bearings. This is where a lot of cheaper gear motor suppliers cut corners, and it’s why they can’t hit those higher speeds. Our RF hypoid gear motors use precision ceramic ball bearings on the pinion shaft, and needle bearings on the ring gear. Why ceramic? Because steel bearings can heat up way faster when spinning at high RPM, and that heat causes expansion, which makes the gears bind. We tested a competitor’s hypoid motor with all steel bearings once, and their maximum safe output speed was only 1200 RPM, even unloaded. Our units can hit 3000 RPM unloaded because the ceramic bearings run 20-30% cooler at high speeds. Also, the gear mesh quality matters—if the hypoid gears aren’t cut with the right spiral angle, the contact between teeth is uneven, so at high speeds, that uneven contact creates vibration. We use computer-controlled cutting machines for our gears, so the tooth profile is consistent, which lets us run those higher speeds without vibration. Vibration is a silent killer for gear motors, too—even if it doesn’t cause immediate breakdown, it wears out the gears 2x faster than it should, which is a headache for customers who need their motors to last thousands of cycles.
Wait, let’s talk about the input motor’s RPM too, because that’s tied in. The RF part of our motor is a brushless DC motor, right? Standard brushless motors top out around 10,000 RPM, but for gear motors, we don’t usually run them that high, because the gear set would take that input speed and turn it into something too fast, leading to too much friction. For our high-speed units, we run the input motor at 6000-7000 RPM, because that’s the sweet spot where the motor is efficient, and the gear set can handle the output speed without issues. If you push the input motor to 9000 RPM, even with a low ratio, the gear set’s centrifugal force on the pinion is too high, and it can warp over time. We had a customer test that once for a drone gimbal prototype, and their motor lasted only 5 hours before the pinion bent. We had to adjust the input speed down to 6500 RPM, and now that same motor runs for 500+ hours no problem.
Another thing I get asked a lot: is there a difference between continuous speed and peak speed? Oh huge. The peak speed I mentioned earlier—3000 RPM unloaded—That’s a short-term thing only, like if you’re testing the motor for a 10-second demo run. If you try to run it at 3000 RPM continuously, the heat buildup from friction would overheat the motor windings, and you’d fry the driver circuit in less than a minute. Our spec sheets list continuous output speed for a reason—for our low-ratio units, that’s usually between 1500 and 2000 RPM, unloaded, and under load it’s 1000-1500 RPM. For high-reduction units, continuous speed is 50-100 RPM, even unloaded, because the gear ratio means the teeth are under more constant stress at any speed over that.
Let me also clear up a common myth: people think hypoid gear motors are only for low-speed, high-torque applications, but that’s not true. We’ve had customers use our high-speed RF hypoid motors for things like automated pick-and-place arms in small warehouses, where they need the arm to move fast but also need the torque to pick up small boxes. The spur gear motors they used before couldn’t handle the speed without vibrating so bad the boxes fell off, but the hypoid design’s offset lets the gears mesh smoother at higher speeds. Another customer used our high-speed units for a medical device—specifically a portable blood analyzer that has to spin a centrifuge rotor to separate blood cells. The hypoid motor was compact enough to fit into the palm-sized device, and it hit 2800 RPM continuous, which was exactly what they needed, whereas a standard spur gear motor was too big and couldn’t get that speed without breaking.
Now, what about the limits? I’ve seen our units go as high as 3200 RPM output unloaded, but that’s on a custom test unit we built for a aerospace component prototype, and even that only lasted 15 minutes before we shut it down because the vibration was starting to affect adjacent sensors. The practical maximum for a standard off-the-shelf RF hypoid gear motor we supply is around 3000 RPM unloaded, and 2000 RPM continuous, low load. If you’re running under heavy load, knock that down to 1200 RPM continuous, no exceptions. Why can’t we go higher? At that point, the centrifugal force on the gear teeth starts to cause them to deflect slightly, which messes up the mesh, and the bearings can’t handle the RPM without wearing out too fast. We’ve tried tuning the gear material (using titanium instead of steel) to handle higher speeds, but that adds too much cost for most customers, so it’s only for custom orders.
Let’s wrap this up with what matters most for you, not just a spec number. If your project needs high speed, first think about your gear ratio. Don’t pick a high ratio just for torque if you don’t need it—lower ratio = faster output. Second, pay attention to load: if your motor will be under constant load, don’t count on peak unloaded speed. Third, make sure the motor is designed for high-speed operation—cheap bearings and cut corners on gear quality will blow up on you way before you hit the maximum.
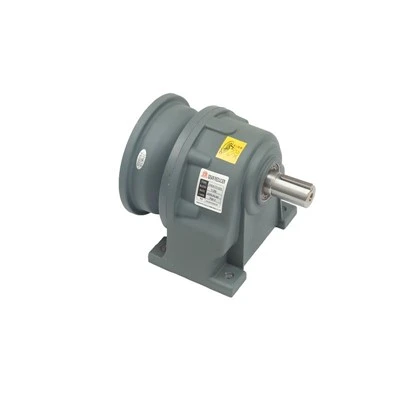
If you’re working on a project right now and trying to figure out what speed your RF hypoid gear motor can handle, we’re here to help. Whether you’re a hobbyist prototyping a small robot, an engineer designing a medical device, or a business scaling up an automation line, we can walk through your specs, test a sample motor if needed, and make sure you get the right unit that hits your speed needs without breaking the bank. Hit us up to chat through your requirements, no sales pitch, just straight talk about what works for your build.
Parallel Shaft Gearboxes References:
- American Gear Manufacturers Association. (2021). Hypoid Gear Design and Performance Standards for Electric Motors. AGMA Publication 125.
- Motion Control Association. (2022). High-Speed Gear Motor Speed Limitations: Bearings, Gear Mesh, and Load Effects. MCA Technical Whitepaper Series.
- National Electronics Manufacturers Association. (2020). RF Brushless Motor Efficiency at High RPM Operations. NEMA Engineering Report 47-20.
GuangDong Ruisico Transmission Technology Co., Ltd.
Guangdong Ruisico Transmission Technology Co., Ltd. is one of the most reliable rf hypoid gear motor manufacturers and suppliers in China, also supports customized service. Welcome to buy durable rf hypoid gear motor made in China here and get quotation from our factory. For price consultation, contact us.
Address: No. 70, Anjing Road, Shengfeng Community, Xiaolan Town, Zhongshan City
E-mail: info@risc-drive.com
WebSite: https://www.risc-motor.com/
